Torque describes the ability of a force to cause rotation about an axis. In practice it appears in the selection of motors and gear units, shaft calculations, and in controlling the tightening of bolted joints. Below, SPEC SERWIS experts will teach you the theoretical basics of torque calculation. At the end of the text you will also find a simple checklist to make your calculations easier.
1) What torque is and how to understand it "from an engineering perspective"
Torque is a vector quantity. It is most often calculated as the cross product of the lever arm vector and the force:
In typical engineering problems we are interested in the magnitude of the torque. If the force acts at an angle θ to the arm r, then:
The SI unit is the newton metre (N·m). It is worth remembering that although N·m has the same dimension as the joule, in technical documentation the N·m notation remains correct for torque.
2) The simplest torque calculation: force on a lever arm
The most common workshop scenario is a lever: you press on a spanner or arm of length r with a force F. If the force acts perpendicular to the arm (θ = 90°), the torque is simply τ = rF.
Example: a spanner 0.30 m long, force 200 N → τ = 0.30 · 200 = 60 N·m.
Typical pitfalls:
- The arm is the perpendicular distance from the axis to the line of action of the force (not the "length of the tool at an angle").
- If the force acts at an angle other than 90°, the real torque drops in line with sin(θ).
3) Torque from power and speed (crucial in drives)
In rotary drives, the basic relationship linking power, torque and angular velocity is:
Angular velocity ω is related to rotational speed n (rpm) by the relationship:
After substitution you get a useful formula for torque:
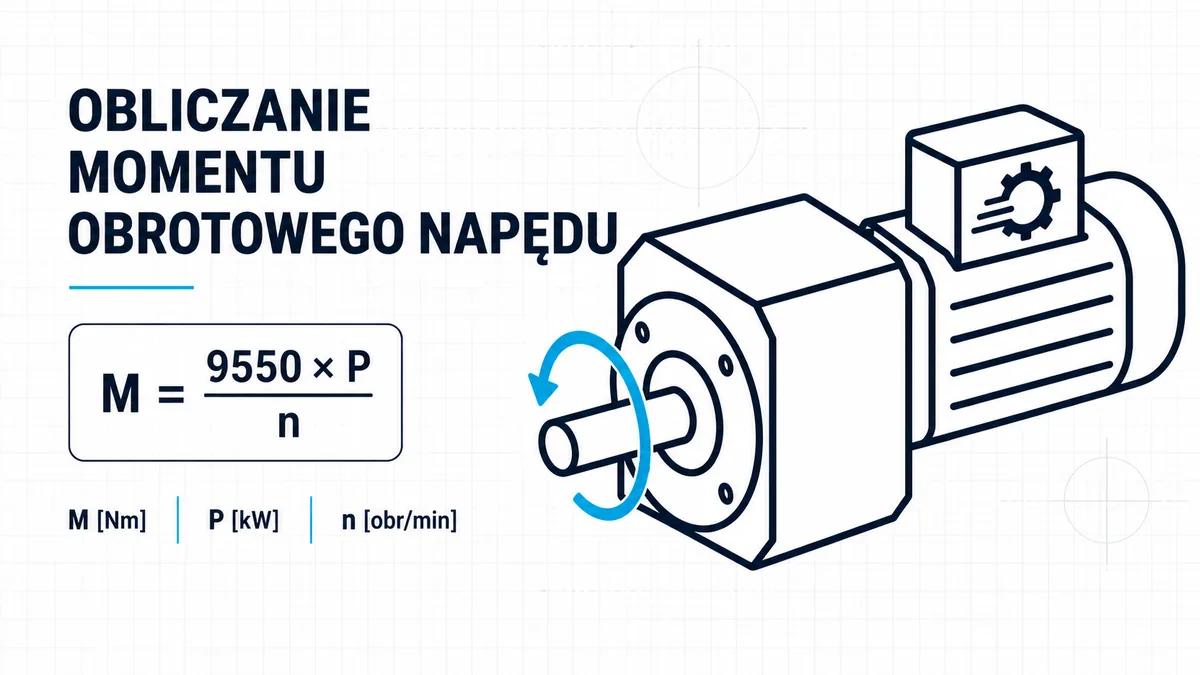
In practice, the shortened version is often used (P in kW, n in rpm):
Example: a 2.2 kW motor at 1450 rpm → τ ≈ (9550 · 2.2) / 1450 ≈ 14.5 N·m.
4) Torque at the gear unit output (drive selection)
For a gear unit, in an engineering approximation (taking efficiency η into account):
Example: τ_in = 14.5 N·m, i = 20, η = 0.92 → τ_out ≈ 14.5 · 20 · 0.92 ≈ 267 N·m.
5) Dynamic torque: inertia and angular acceleration
When the system accelerates or brakes, a dynamic component appears, dependent on the moment of inertia I:
This explains why starting conveyors, drums or rotary tables can require significantly more torque than steady-state operation.
6) Bolt tightening torque: why "Nm" alone can be deceptive
In bolted joints, tightening torque is only an indirect method of achieving the preload force. A significant part of the torque is consumed by friction in the thread and under the bolt head/nut, so the repeatability of the clamping force may be limited.
In practice, a simplified relationship is used:
where K (nut factor) is sensitive to lubrication, coatings and roughness. For critical applications, torque–clamp force test procedures are used (e.g. ISO 16047).
7) How to calculate torque correctly – a working procedure (checklist)
- Define the axis of rotation and the point of application of the force.
- Determine the arm r as the perpendicular distance from the axis to the line of action of the force.
- Establish the angle θ between the arm and the force (does the force act perpendicularly?).
- Choose the right model: lever statics, a drive (power/speed) or dynamics (I·α).
- Reconcile units and conversions (especially rpm ↔ rad/s; kW ↔ W).
- If a gear unit is present, take the gear ratio i and efficiency η into account.
- When the result is "borderline", add a margin for overloads, temperature, friction and process tolerances.
The most common calculation errors (and how to avoid them)
- Confusing the tool length with the perpendicular arm (a geometry error).
- Omitting the angle of action of the force (no sin(θ) factor).
- Calculating torque from power without a correct rpm → rad/s conversion (hence it is worth remembering the 9550 shortcut).
- Treating tightening torque as a guaranteed clamping force without controlling friction and the measurement methodology.
- Confusing unit notation: in documentation, use N·m for torque (not J).
FAQs
Are torque and "force" the same thing?
No. Force [N] describes a linear interaction, while torque [N·m] takes the arm and the ability to cause rotation into account: τ = rFsin(θ).
What is the quickest way to calculate torque from motor power?
Use the formula τ [N·m] ≈ 9550·P[kW] / n[rpm], which follows from the relationship P = τ·ω.
Why doesn't the same tightening torque always give the same clamping force?
Because friction (in the thread and under the head/nut) depends, among other things, on grease, coatings and roughness. For critical applications, torque–clamp force test methods are used (e.g. ISO 16047).
How can we be sure that N·m is the correct unit of torque?
The SI distinguishes the notation and meaning of the unit: despite dimensional equivalence with J, the N·m notation is used for torque so as not to confuse it with energy.